Before integrating, check what happens when x changes to −x. An odd function has f(−x)=−f(x), so its positive and negative contributions cancel over symmetric limits. An even function has f(−x)=f(x), so you can integrate one half and double it.
For example, if a>0,
∫−aa((x2+a2)3/2x+x2)dx=0+2∫0ax2dx=32a3.
The first term disappears without an antiderivative. This is the same cancellation used when opposite charge elements produce equal and opposite field components.
If the numerator lacks the needed factor of x, a trig substitution may work better. For ∫dx/x2+a2, set x=atanθ so the square root becomes asecθ on −π/2<θ<π/2. The integral reduces to ∫secθdθ and gives the logarithmic form listed above.
Use it when differentiating one factor makes the remaining integral simpler. For an exponentially decaying signal with decay rate γ>0,
∫0∞te−γtdt,
choose u=t and dv=e−γtdt. Then du=dt and v=−e−γt/γ, giving
∫0∞te−γtdt=[−γte−γt]0∞+γ1∫0∞e−γtdt=γ21.
The boundary term vanishes because the exponential decays faster than t grows. LIATE—logarithmic, inverse trig, algebraic, trig, exponential—is a useful order to try when choosing u, but the goal is always to simplify the new integral.
Sometimes you already know a related integral. Differentiating it can bring down the extra factor you need. Start with the Gaussian integral
I(a)=∫0∞e−ax2dx=2πa−1/2,a>0.
Differentiating with respect to a gives
I′(a)=−∫0∞x2e−ax2dx=−4πa−3/2.
Therefore,
∫0∞x2e−ax2dx=4a3/2π.
The differentiation and integration can be exchanged here because the integrand and its derivative decay sufficiently fast for positive a. For variable integration limits, include their boundary terms using Leibniz’s rule.
When doing physics problems, we use the small angle approximation for simplification. For ∣x∣≪1:
Function
Approximation
(1+x)n
1+nx
ex
1+x
ln(1+x)
x
sinx
x
cosx
1−21x2
tanx
x
1−x1
1+x
The binomial one, (1+x)n≈1+nx, is useful throughout physics: it linearizes square roots (1+x≈1+2x), reciprocals, and many other complicated polynomial expressions. In practice, factor out the large quantity first so that the expansion parameter is small. As an example,
R2+x21=R11+(x/R)21≈R1(1−2R2x2)(x≪R).
Example. Two equal masses M are fixed a distance 2a apart. A much smaller mass m lies on their perpendicular bisector, a distance y from the midpoint, where ∣y∣≪a. Find the small mass’s approximate acceleration and its oscillation frequency.
The horizontal gravitational forces cancel. The vertical acceleration is
ay=−(a2+y2)3/22GMy.
The useful small quantity is not y itself but y2/a2. Factor out a2 before expanding:
(a2+y2)−3/2=a−3(1+a2y2)−3/2≈a−3(1−2a23y2).
Because the numerator already contains y, the correction is third order. To first order,
ay≈−a32GMy.
This has the SHM form y¨=−ω2y, so
ω=a32GM.
The creative step is recognizing that an inverse-power gravitational expression becomes a spring law after expanding about the midpoint.
Sometimes, when you have a≪b, you can perform a Taylor expansion at x=0 (this is how we derive all of the small value approximations above!). The general expansion of a function about x=0 (a Maclaurin series) is
f(x)=f(0)+f′(0)x+2!f′′(0)x2+3!f′′′(0)x3+⋯
If you are doing oscillations/SHM calculations, you need to take up to the second derivative (quadratic) term, and if you are doing any other calculations you usually only need to take up to the first derivative (linear) term.
Example. Why does a stable equilibrium cause SHM?
Take any potential U(x) with a stable equilibrium at x0. Expand about x0:
The constant doesn’t affect forces, and the linear term is zero at equilibrium, so near x0
U(x)≈const+21keff(x−x0)2,keff=U′′(x0).
This is a spring potential with effective spring constant U′′(x0), so the system oscillates with ω=U′′(x0)/m. Any smooth potential looks like a harmonic oscillator near its minimum — this is why SHM is everywhere, and why USAPhO loves asking for “the frequency of small oscillations.”
As an example, a pendulum has U(θ)=mgL(1−cosθ)≈21mgLθ2 for small θ (keeping the quadratic term), giving ω=g/L.
Choose coordinates that follow the symmetry of the problem. A good coordinate system makes boundaries constant-coordinate surfaces and points one basis vector along the direction in which the system changes.
Use polar coordinates for motion confined to a plane around a fixed point: circular tracks, central-force orbits, rotating rods, or circular area integrals. A circle becomes the simple condition r=R. If the path and forces instead follow straight perpendicular directions, Cartesian coordinates may be easier.
Polar coordinates describe a point in a plane using its distance r from the origin and angle θ from the positive x-axis:
x=rcosθ,y=rsinθ,dA=rdrdθ.
The basis vectors r^ and θ^ rotate as the particle moves. Their derivatives are
dtdr^=θ˙θ^,dtdθ^=−θ˙r^.
Therefore,
v=r˙r^+rθ˙θ^,a=(r¨−rθ˙2)r^+(rθ¨+2r˙θ˙)θ^.
Example. A bead slides freely on a straight radial rod rotating at constant angular speed ω in a horizontal plane. Find the equation governing its distance r from the pivot.
In Cartesian coordinates, both the rod and its constraint force constantly change direction. In polar coordinates the constraint is simply θ=ωt, so θ˙=ω and θ¨=0. The rod’s force is perpendicular to the rod, so there is no radial force. The radial component of Newton’s second law is
0=m(r¨−rω2),
or
r¨=ω2r.
The coordinate choice eliminates the unknown constraint force from the equation we need.
Use spherical coordinates when distances and boundaries are measured from one center: spheres, shells, radial density distributions, and point-charge or gravitational fields. For full spherical symmetry the angular integrals give 4π, leaving a single radial integral. A hemisphere uses a restricted polar-angle range.
Spherical coordinates use distance r from the origin, polar angle θ measured down from the positive z-axis, and azimuthal angle ϕ around the z-axis:
x=rsinθcosϕ,y=rsinθsinϕ,z=rcosθ.
The volume element and area element on a sphere are
dV=r2sinθdrdθdϕ,dAr=r2sinθdθdϕ.
For a spherically symmetric scalar field f(r),
∇f=drdfr^,∇2f=r21drd(r2drdf).
Example. A sphere of radius R has density ρ(r)=ρ0r/R. Find its total mass.
Because the density depends only on distance from the center, spherical shells are constant-density surfaces. Using dV=4πr2dr after integrating over the angles,
M=∫ρdV=4π∫0RRρ0rr2dr=R4πρ0[4r4]0R=πρ0R3.
In Cartesian coordinates, the same integral would require a spherical boundary and a density containing x2+y2+z2.
Use cylindrical coordinates for symmetry about an axis: long wires, pipes, coaxial capacitors, rotating cylinders, and disks or stacks of disks. A cylindrical wall is s=R, while flat end caps are constant z. This separates distance from the axis from height along it.
Cylindrical coordinates combine polar coordinates in the xy-plane with an ordinary vertical coordinate:
x=scosϕ,y=ssinϕ,z=z,
where s is the perpendicular distance from the z-axis. The volume element and common surface elements are
dV=sdsdϕdz,dAs=sdϕdz,dAz=sdsdϕ.
Using s rather than r avoids confusing cylindrical distance from the axis with spherical distance from the origin.
Example. A solid cylinder of radius R, length L, and uniform density ρ rotates about its symmetry axis. Find its moment of inertia.
Every mass element’s perpendicular distance from the axis is simply s. Therefore,
A vector a has components a=(ax,ay,az)=axi^+ayj^+azk^, where i^,j^,k^ are unit vectors along the axes. Its magnitude (or norm) is ∣a∣=ax2+ay2+az2, and the unit vector in its direction is a^=a/∣a∣. Throughout, θ denotes the angle between the two vectors being combined.
Definition (Dot product). The dot product is one way to multiply two vectors, and result in a scalar quantity. The formula is given by: a⋅b=axbx+ayby+azbz
Properties:
a⋅b=∣a∣∣b∣cosθ
b⋅a=a⋅b
a⋅a=∣a∣2
If a⊥b, then a⋅b=0
The dot product acts like a projection: a⋅b^ is the component of a along the direction of b. This is why work is W=F⋅d and flux is E⋅A, since both measure components along a specific direction.
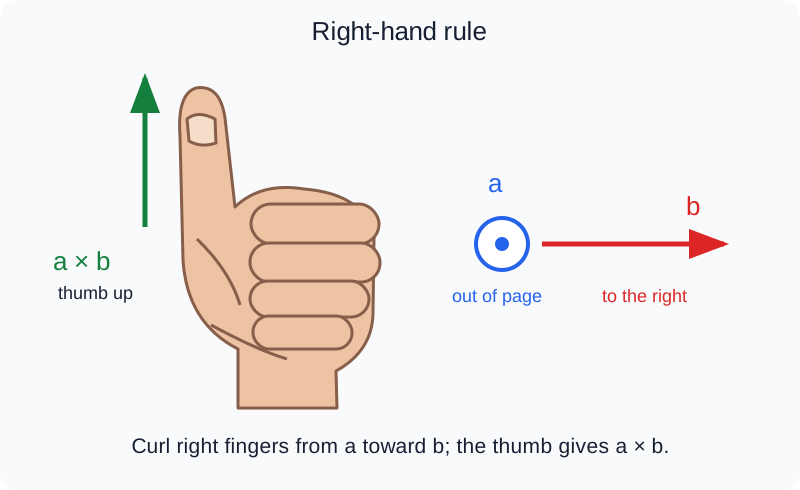
Definition (Cross product). The cross product is one way to multiply two vectors, and result in another vector, whose direction is perpendicular to the first two. You find the direction based on the right-hand rule (as described in AP Physics C). The formula is given by the determinant
∣a×b∣=∣a∣∣b∣sinθ — the magnitude equals the area of the parallelogram spanned by the two vectors.
b×a=−a×b (anticommutative — order matters!)
a×a=0, and more generally a×b=0 if a∥b.
The result is perpendicular to both inputs, with direction set by the right-hand rule.
To apply the right-hand rule, point the fingers of your right hand along the first vector, curl them through the smaller angle toward the second vector, and point your thumb perpendicular to the plane. Your thumb gives the direction of a×b. Reversing the order reverses the direction. For vectors in the page, counterclockwise rotation from the first vector to the second gives a result out of the page, while clockwise rotation gives a result into the page.
The cross product denotes a “rotational” or perpendicular quantity: torque τ=r×F, angular momentum L=r×p, and magnetic force F=qv×B are all cross products.
Often times, problems require a combination of the dot and cross products.
The scalar triple product gives a signed volume:
a⋅(b×c)=b⋅(c×a)=c⋅(a×b).
Its magnitude is the volume of the parallelepiped spanned by the three vectors. Swapping any two vectors changes the sign. If the triple product is zero, the vectors are coplanar.
The vector triple product follows the BAC–CAB rule:
a×(b×c)=b(a⋅c)−c(a⋅b).
Cross products are not associative, so parentheses matter. Two other useful identities are
Example. A particle of charge q moves with velocity v in a uniform magnetic field B. Using F=qv×B, find dF/dt when no other forces act, and show that the acceleration rotates about B.
Since B is constant,
dtdF=qdtdv×B=mqF×B=mq2(v×B)×B.
Apply the vector triple product with the parentheses in this order:
(v×B)×B=B(v⋅B)−vB2=−B2v⊥.
Therefore,
dtdF=−mq2B2v⊥.
The force changes toward the center of the circular perpendicular motion while the component of velocity parallel to B stays constant. This is the vector form of helical motion.
Sometimes, you have to think outside of the real numbers. As you may remember from precalculus, any sinusoid can be written as the real part of a complex exponential, using Euler’s formula
eiθ=cosθ+isinθ.
So Acos(ωt+ϕ)=Re(Aeiϕeiωt). Differentiation then becomes multiplication by iω, which turns the differential equations of oscillations and AC circuits into ordinary algebra. Adding two waves of the same frequency becomes adding two complex numbers (“phasors”) tip-to-tail, which can avoid hefty trig identities.
Example. Two perpendicular simple harmonic motions have the same angular frequency:
x(t)=Acosωt,y(t)=Acos(ωt+32π).
Find the amplitude and phase of the motion along the line u=(x+y)/2.
Represent each cosine by its complex amplitude. The complex amplitude of u is
U~=2A(1+ei2π/3).
Using 1+eiα=2cos(α/2)eiα/2,
U~=2Aeiπ/3.
Taking the real part at the end gives
u(t)=2Acos(ωt+3π).
Thus the projected motion has amplitude A/2 and phase π/3. The phasor sum avoids expanding and recombining several sine and cosine terms.